Hardware

Robots & Platforms

The platforms, sensors, and computing hardware that power our field experiments.

Note for lab members: the entries below are placeholders to establish the page structure. Update _data/robots.yml with the lab's actual platforms, photos, and sensor suites.

Underwater Robots

TODO

Underwater Vehicle — TODO

TODO: describe the lab's underwater platform used for marine perception and mapping (e.g., ROV / AUV model).

Sensors: Stereo camera, Imaging sonar, IMU, Depth sensor

Related projects: Underwater Perception for Marine Ecosystem Monitoring
Ground Robots

TODO

Mobile Ground Robot — TODO

TODO: describe the lab's ground platform used for field robotics and autonomy experiments.

Sensors: RGB-D camera, LiDAR, IMU, Wheel odometry

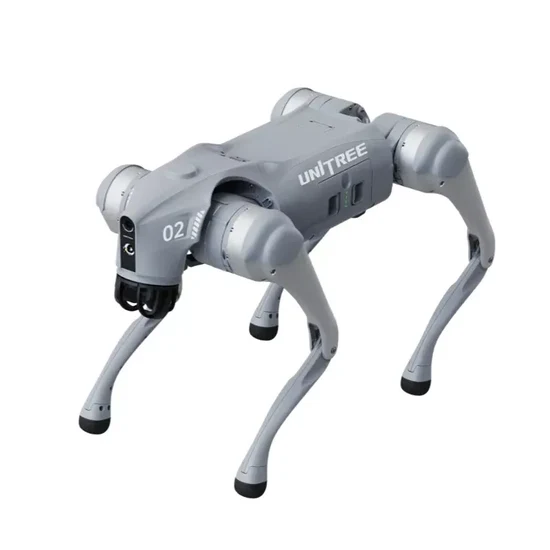
ActiveUnitree GO2

Unitree GO2

Unitree GO2: Quadruped robot dog used for LiDAR-based 2D and 3D indoor mapping and autonomous building inspection.

Sensors: 4D LiDAR L1, RGB camera, IMU

Sensor Platforms

TODO

Multimodal Sensor Rig — TODO

TODO: describe the camera / LiDAR / sonar sensor suite used for multimodal perception and data collection.

Sensors: Camera array, LiDAR, Sonar

Related projects: PFS

Computing Hardware

TODO

Edge Compute — TODO

TODO: describe the lab's edge computing hardware for on-board AI (e.g., NVIDIA Jetson class devices).

Related projects: Edge AI & LLM Reasoning for Robotics