What we do

Research

We develop perception and autonomy for robots that operate in challenging, unstructured, and safety-critical environments.

Underwater Robot Perception

Perception and autonomy for underwater vehicles operating in turbid, dynamic, and GPS-denied marine environments.

3D Computer Vision

Multimodal 3D detection, reconstruction, and scene understanding from cameras, LiDAR, and sonar.

Multimodal Learning

Fusing heterogeneous sensors and modalities into robust representations for real-world robotic decision-making.

Embodied AI

Agents that perceive, reason, and act — closing the loop between perception, planning, and control on physical platforms.

Autonomous Systems

Long-term autonomy for field robots, including navigation, mapping, and control in challenging environments.

Synthetic Data & Digital Twins

Simulation-based data generation and digital twins that bridge the sim-to-real gap for perception models.

Edge AI for Robotics

Efficient algorithms and hardware-aware frameworks that bring perception and reasoning onto resource-constrained edge devices.

LLMs for Robotics Reasoning

Integrating large language models and knowledge graphs for higher-level robot reasoning and decision-making.

Selected work

Projects

ICDL 2026LADBench: A Benchmark for Logical Anomaly Detection in Images thumbnail

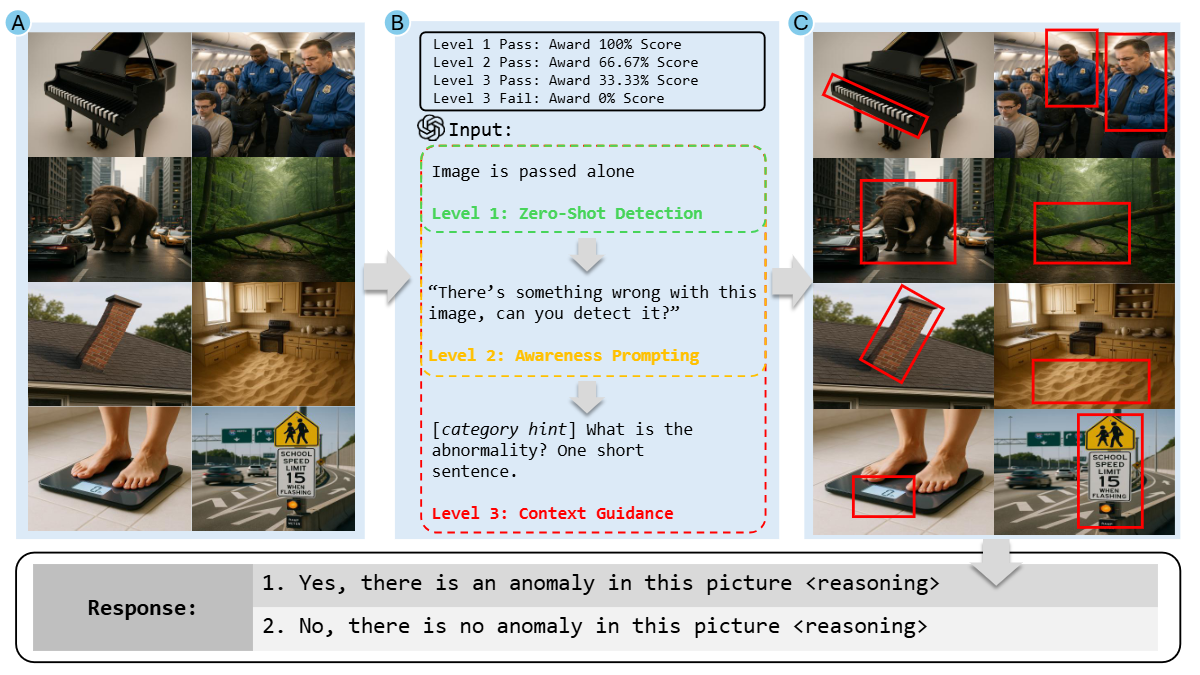
LADBench: A Benchmark for Logical Anomaly Detection in Images

A benchmark to measure common sense logical reasoning of Vision Language Models using curated synthetic images with defined logical anomalies accross real life categories to improve VLM preparedness for open world deployment.

Vision Language ModelsLogical Anomaly DetectionMultimodal ReasoningVisual Question Answering

Sahasra Kondapalli, Lara Radovanovic, Aadi Palnitkar, Mingyang Mao, Xiaomin Lin

IROS Workshop · Best PaperOdyssee: Autonomous Robotic Systems for Aquaculture thumbnail

Odyssee: Autonomous Robotic Systems for Aquaculture

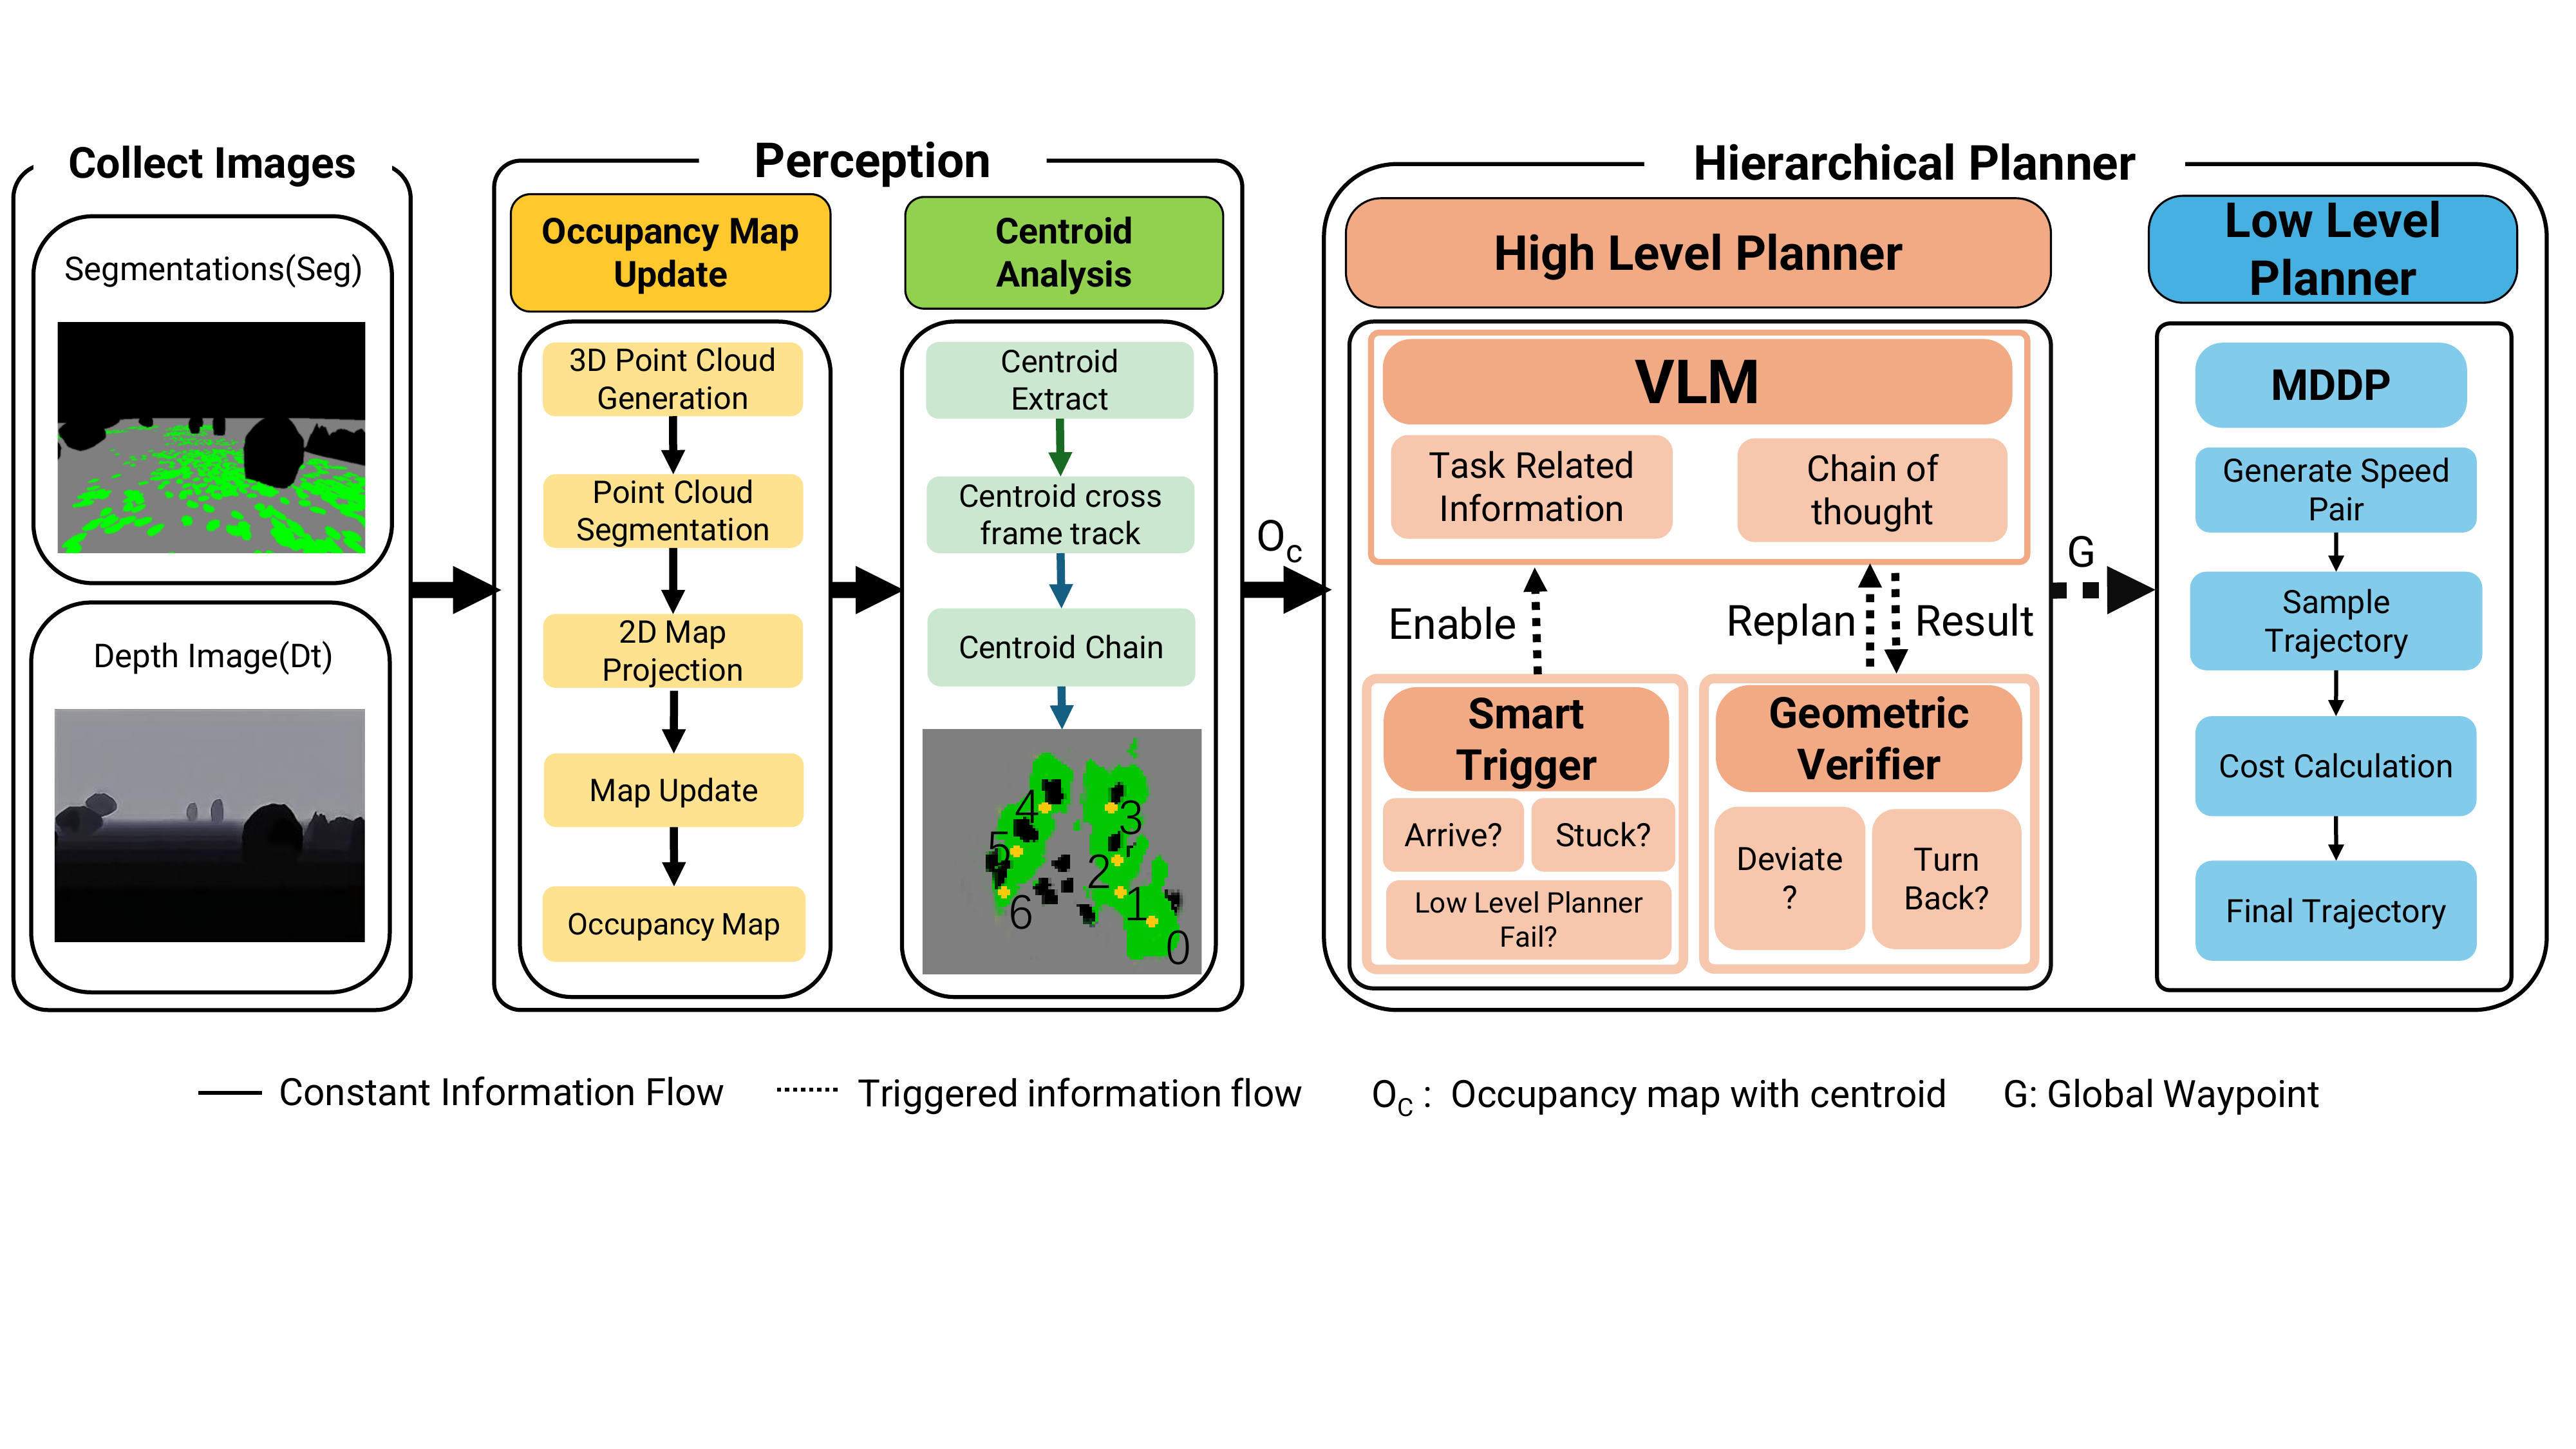
A multi-institution effort on autonomous navigation and control for aquaculture monitoring, recognized with the best control framework award at the IROS workshop in Abu Dhabi. Led by Prof. Xiaomin Lin as lead and corresponding author.

Field RoboticsAutonomyAquacultureMarine Robotics

Xiaomin Lin

Underwater Perception for Marine Ecosystem Monitoring thumbnail

Underwater Perception for Marine Ecosystem Monitoring

Frameworks for autonomous underwater vehicles to detect and map marine objects such as oyster beds and coral reefs, combining real and synthetic data, simulation-based methods, and multimodal sensing.

Underwater Robotics3D VisionPerceptionEnvironmental Monitoring

Xiaomin Lin

Synthetic Data & Digital Twins for Robotics thumbnail

Synthetic Data & Digital Twins for Robotics

Simulation-based synthetic data generation and digital-twin pipelines that bridge the sim-to-real gap for perception models deployed on field robots.

Synthetic DataDigital TwinSimulationSim-to-Real

Xiaomin Lin

Edge AI & LLM Reasoning for Robotics thumbnail

Edge AI & LLM Reasoning for Robotics

Efficient algorithms and frameworks for deploying perception and reasoning on edge devices, including integrating large language models with knowledge graphs for robot decision-making.

Edge AILLMKnowledge GraphsEmbedded Systems

Xiaomin Lin