IROS 2026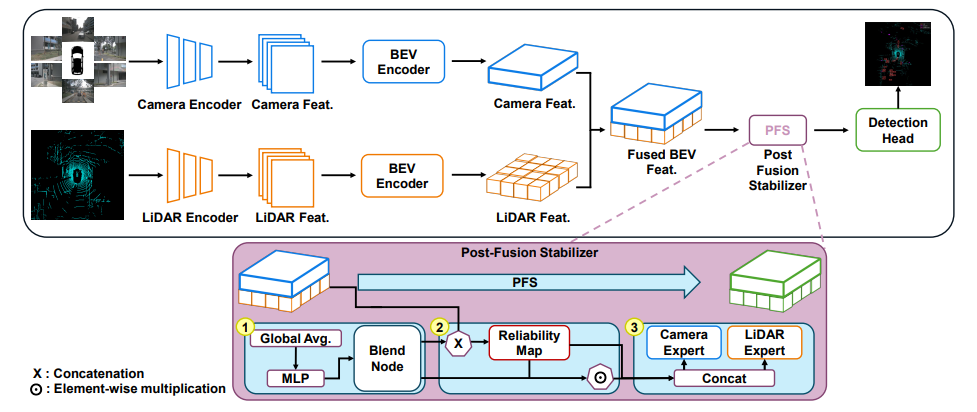
PFS: Post-Fusion BEV Feature Stabilization for Robust Multimodal 3D Detection
A lightweight, near-identity module that stabilizes intermediate bird's-eye-view features of existing camera–LiDAR detectors, improving robustness under domain shift and sensor degradation without retraining the detection head.